Waymo's manifesto reframes the autonomy debate
Every hiker knows the sting of a false summit: hours of effort, aching legs and the bitter realization that the true peak still lies beyond a steeper ridge. Alphabet's Waymo is using the same metaphor to challenge a major assumption in the race to commercialize self-driving cars — and the target is obvious even when unnamed.
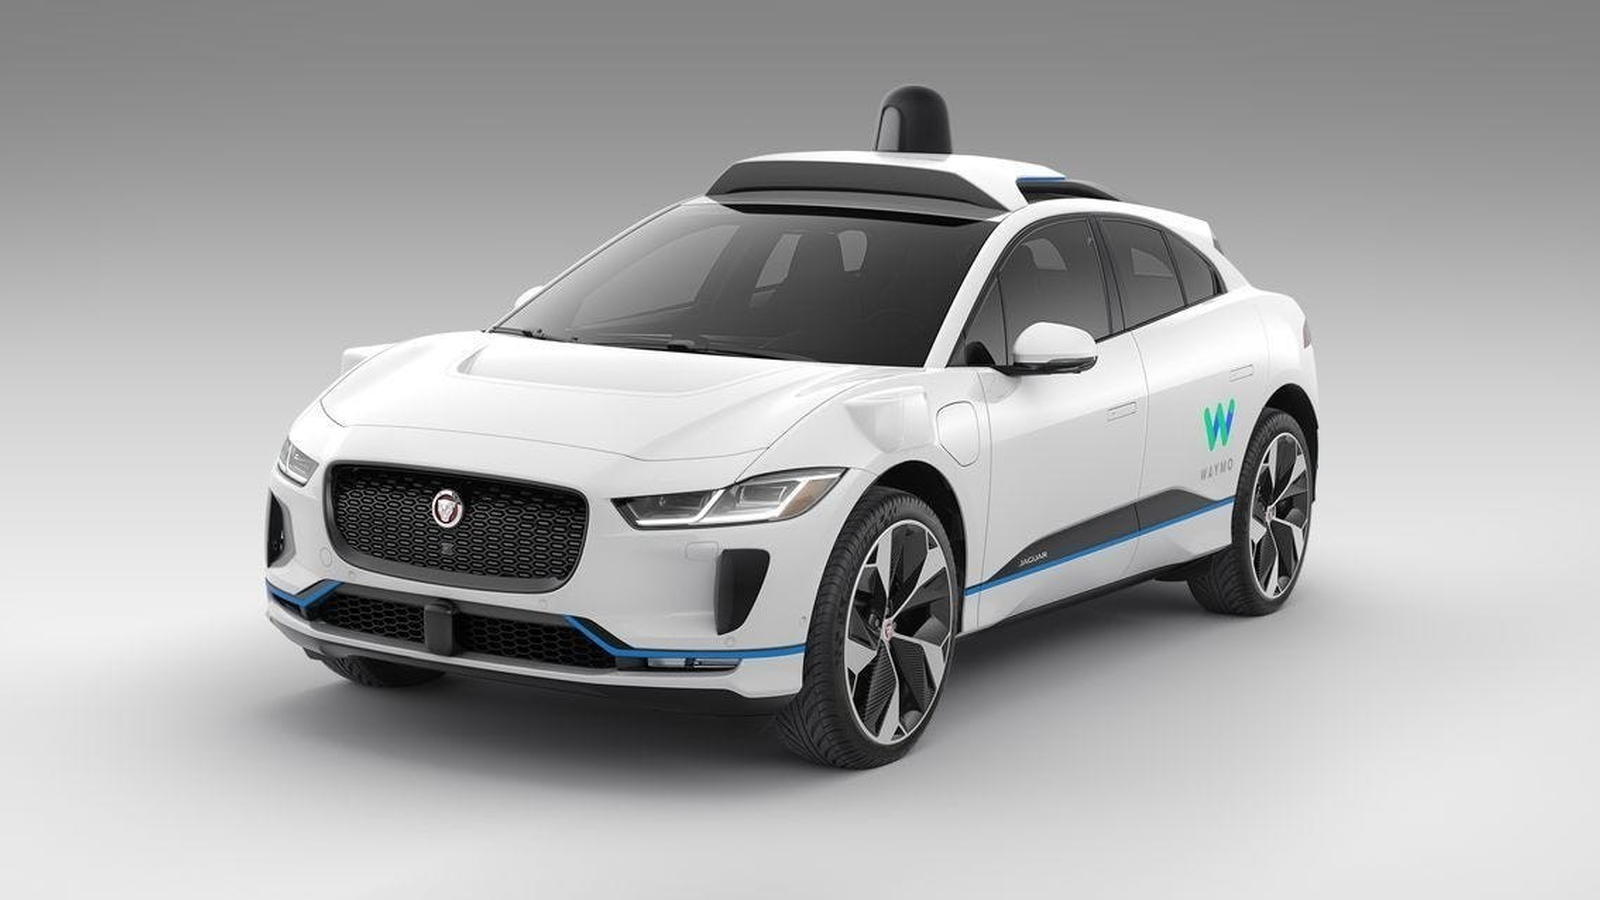
Earlier this year Waymo published an engineering treatise by Srikanth Thirumalai, head of AI foundations, distilled from more than 200 million fully driverless miles. What reads like a machine-learning safety paper is also a direct rebuttal to the idea that advanced driver-assist systems will naturally evolve into safe, scalable robotaxi fleets.

‘False summit’: why Level 2 can’t simply morph into Level 4
Waymo calls the notion that a sophisticated Level 2 driver-assist package can be iteratively upgraded into true Level 4 autonomy a 'false summit'. The argument is stark: billions of simulated miles and millions of highway miles collected from customer vehicles do not substitute for the moment an AI must make safety-critical decisions without a human backup within reach.

As long as a human is legally responsible and ready to intervene, the system avoids confronting edge-case consequences of its choices. That creates a training and evaluation gap that, according to Waymo, no amount of software iteration can bridge alone.
Sensor fusion vs. camera-only philosophy
One of the most pointed lessons targets hardware philosophy. Tesla removed radar and ultrasonic sensors years ago and placed a bold bet on camera-only perception plus neural networks. Waymo argues multimodal sensor fusion—combining cameras, lidar and radar—is non-negotiable for reliable perception across weather, lighting and occlusion scenarios.

Cameras excel at reading signs and lights, but they falter in glare, heavy spray or low sun angles. Lidar builds millimeter-accurate 3D geometry; mmWave radar penetrates rain, fog and dust. Waymo pairs high-resolution optical cameras with rooftop spinning lidar and radar to form overlapping layers of redundancy.
The market is already reacting. Chinese automakers are accelerating the hardware arms race: XPeng’s mid-size G6 ships with dual-lidar arrays in a package priced around €50,000 in some overseas markets, showing advanced sensor redundancy can be made more affordable than many expected.

Hardware and cost: the trade-offs
- Tesla: lightweight, cost-efficient consumer sensors and heavy reliance on software
- Waymo: higher upfront hardware cost for redundancy and safety
- Chinese OEMs: increasingly competitive, adding lidar and advanced stacks to mid-range models
These approaches reflect different risk appetites: scale fast and rely on software, or invest heavily in sensing and safety from day one.

End-to-end neural nets vs. layered architectures
Waymo also warns against full end-to-end neural networks that map raw camera pixels directly to steering, throttle and braking. While elegant and powerful, pure black-box models are inherently hard to audit when lives are at stake.
Instead, Waymo describes a 'thinking fast and slow' architecture: rapid sensor fusion for reflexive, split-second control, combined with larger vision-language models for deep scene understanding. Crucially, an independent onboard AI validation layer monitors outputs and intervenes if a commanded action violates traffic law or risks a collision. If a model hallucinated a clear lane into a construction barrier, the safety backstop brakes automatically.
This layered approach aims to make decision pathways auditable and failures predictable — a key point for regulators and insurers.
Operational reality: rides and miles
Theory meets business in Waymo's operating numbers. The company reports more than 500,000 paid, fully driverless rides each week across multiple U.S. cities, including Phoenix, San Francisco, Los Angeles, Austin, Dallas, Houston, San Antonio and Orlando. Waymo has publicly set sights on reaching one million weekly rides before year-end.
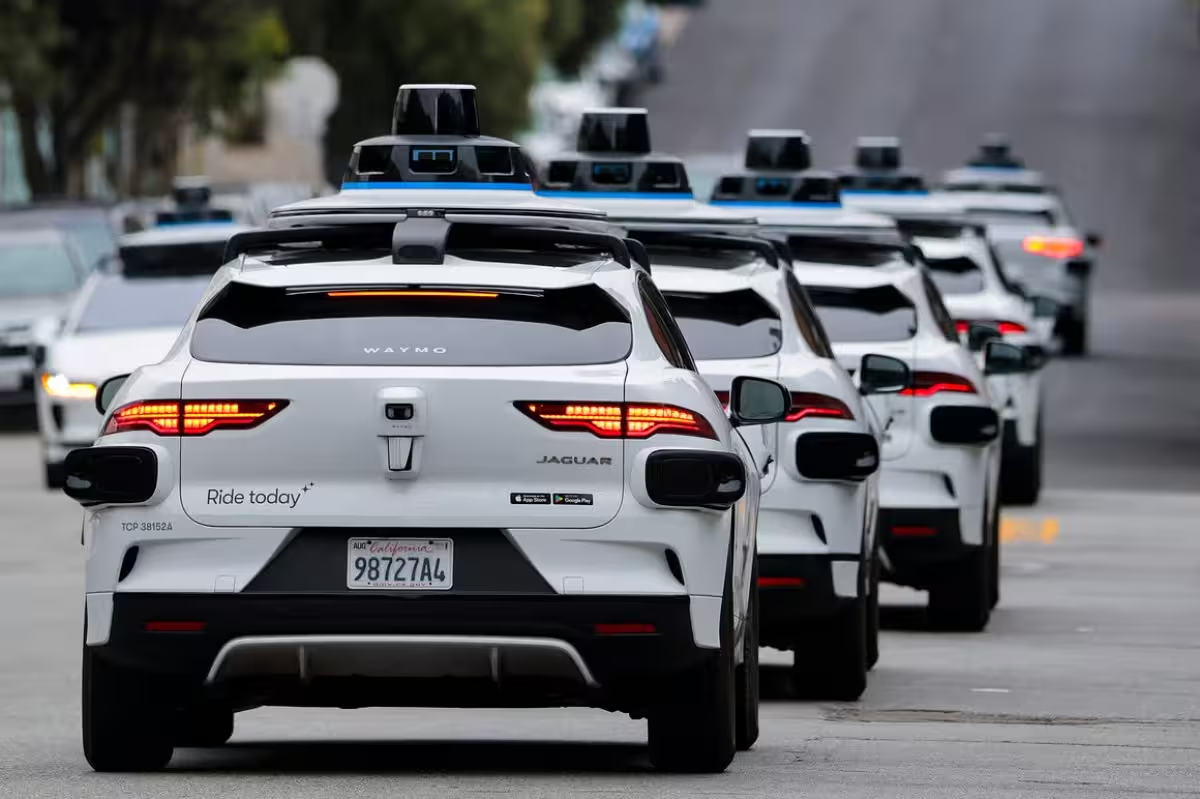
By contrast, Tesla’s limited robotaxi pilot in Austin — still operating with human safety monitors — logged about 380,000 unsupervised miles in a year. Waymo’s commercial fleet covers that distance in roughly a day. Those differences underscore why investors, insurers and city planners treat Waymo and Tesla as fundamentally different operational models, not just competitors with different logos.
Key operational takeaways
- Scale matters: continuous commercial operation exposes systems to a broader variety of edge cases.
- Legal responsibility: who is accountable when an autonomous system errs remains central to deployment strategy.
- Auditable decisions: regulators will likely favor systems that can explain or constrain their behavior.
Market implications and the road ahead
The debate is not purely academic. It shapes product roadmaps, partnerships and regulatory approvals. Tesla’s OTA-driven updates and camera-first strategy promise faster rollouts and lower per-vehicle costs. Waymo’s multi-sensor, safety-first approach demands more upfront investment but targets predictable performance and auditable safety.
Chinese automakers complicate the picture. By integrating lidar and backup sensors into mid-priced EVs, they blur the lines between expensive safety-heavy fleets and mass-market autos. That competition could accelerate adoption of sensor-rich architectures across global markets.
Quote highlight
'You can log billions of miles in simulation,' Waymo’s paper effectively says, 'but until the system is legally and functionally responsible without a human, it hasn't faced reality.'
Conclusion: a climb with many routes
Standing on a lower ridge, it's tempting to think the summit is within reach. Waymo’s manifesto argues that true Level 4 autonomy requires different gear: multimodal sensors, layered AI architectures, independent safety backstops and the humility to admit what current camera-only systems might miss.
That doesn't guarantee Waymo's blueprint will be the final answer. The automotive world has surprised skeptics before. Elon Musk and Tesla still have the resources and ambition to prove critics wrong. But for now the data—hundreds of millions of driverless miles and hundreds of thousands of weekly commercial rides—gives Waymo a powerful claim: some peaks can only be reached with the right tools and a respect for how steep the climb truly is.

Whether the industry adopts Waymo's route or finds a new path, the next few years will determine which approaches scale safely and which remain marked on the map as false summits.
Discussion
Leave a Comment
Comments (2)
Is this even true? logging billions in sim miles still avoids real panic moments, right... curious how regulators decide
wow, didn't expect Waymo to lay it out so bluntly. Camera-only feels risky now, lidar looks like common sense tbh. But cost??